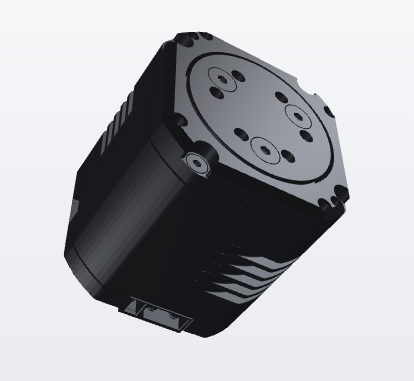
JM012
Integrated hollow rotary joint
- Peak torque
- 12 N·m
- Rated torque
- 3.85 N·m
- Peak speed
- 100 rpm
- Weight
- 165 g
- Dimensions
- 40×40×43.2 mm
- Hollow shaft bore
- None
Highlights
Compact and light
40×40×43.2 mm / 165 g
High torque density
Peak torque density of 73 N·m/kg
Precise positioning
Repeatability ≤±0.01°
Sustained peak output
Peak torque held for 10 s or more
Smooth running
Torque fluctuation ≤5%, no jerk
Quiet operation
Noise below 60 dB(A) at 50 cm
Industrial durability
Over 500 h of ageing tests, full protection set
Low-latency response
Control response twice as fast as the industry norm
Typical Applications
- Robot wrist
- Robot elbow
- Robotic arm joint
Specifications
Model: JM012
Mechanical
- Dimensions
- 40×40×43.2 mm
- Weight
- 165 g
- Hollow shaft bore
- None
- Encoder type
- Dual encoder
- Peak torque density
- 73 N·m/kg
- Reducer type
- Two-stage planetary reducer
- Gear ratio
- 36
- Backlash
- 20 arcmin
- Bearing type
- Four-point contact bearing
Electrical & Performance
- Rated torque
- 3.85 N·m
- Peak torque
- 12 N·m
- Rated speed
- 120 rpm
- Peak speed
- 100 rpm
- Rated voltage
- 48 V DC
- Rated phase current
- 2 Arms
- Rated DC bus current
- 3 Arms
- Rated efficiency
- 68%
- Torque ripple (FFT)
- ≤5%
- Peak torque (3 s)
- 12 N·m
- Peak phase current
- 5.5 Apeak
- Torque fluctuation
- ≤5%
- No-load speed
- 240 rpm
- Cogging torque
- <0.012 N·m
- Back-EMF total harmonic distortion
- ≤5%
- Torque constant
- 2.18 N·m/Arms
Control & Communication
- Communication
- CAN2.0 / CAN FD
- Positioning accuracy
- ≤0.01°
- Repeatability
- ≤±0.01° + backlash
- Hybrid force/position control
- Supported
- Torque control
- Supported
Reliability
- Noise (at 50 cm)
- <60 dB(A)
- Operating temperature
- -40 ~ 85 °C
- Over-temperature / over- and under-voltage / over-current protection
- Supported
- Stall protection
- Supported
Dimensions
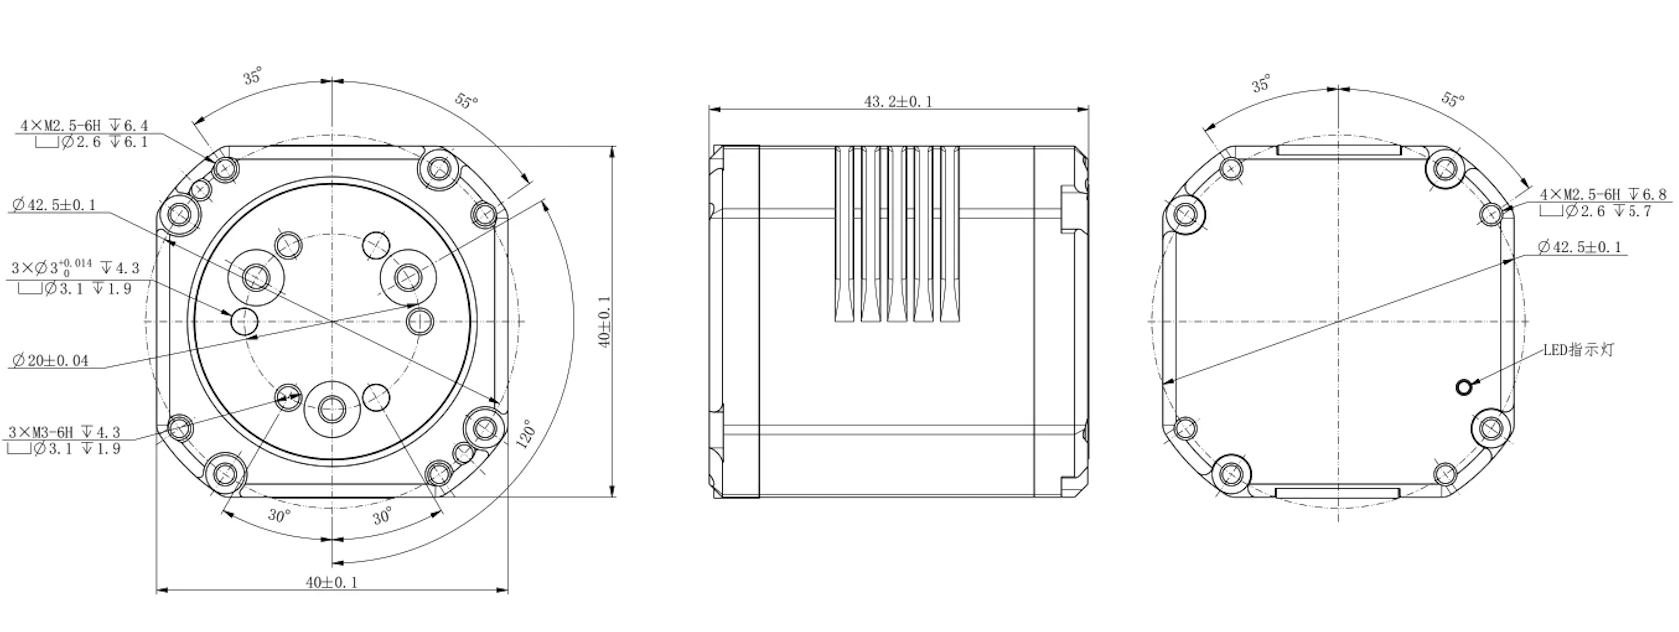
Outline drawing
Torque / Speed Characteristic (TN Curve)
Peak characteristicRated torque 3.85 N·m
Hover the curve to read values